Close
All Categories
    Filters
    Preferences
    Search

    Cubenode ETH

    CubeNode ETH is an interface module from CubePilot designed to provide high-speed Ethernet networking to Cube flight controllers;(such as Cube Orange+ and Cube Red) that lack native Ethernet support.

    MFR Part #: CP-06328
    $70.00
    Key Features & Performance
    • Networking Speed: Provides a networking link of up to 12 Mbps using the Point-to-Point Protocol (PPP).
    • Protocol Support: Transports multiple protocols, including CAN and MAVLink, over the network without exhausting multiple serial ports.
    • Processor: Powered by a dual-core Arm Cortex-M7 (480 MHz) and Cortex-M4 (240 MHz) architecture with high-speed embedded memories (2MB Flash, 1MB RAM).
    • Compliance: The device is NDAA compliant, with components sourced and assembled in Allied nations.
    Compatibility
    • Flight Controllers: Native support is available for Cube Orange+ and Cube Red running ArduPilot 4.5 or higher. Older Cubes may require custom ArduPilot builds with networking enabled.
    • Software Ecosystem: Compatible with the Cube Autopilot ecosystem and UAVCAN/DroneCAN devices. 

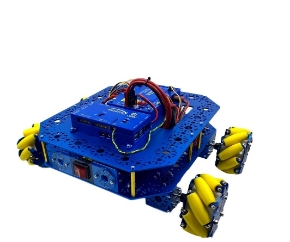
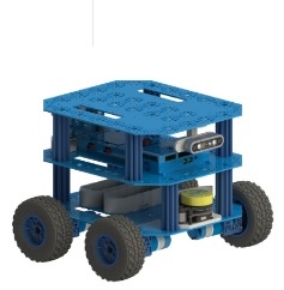
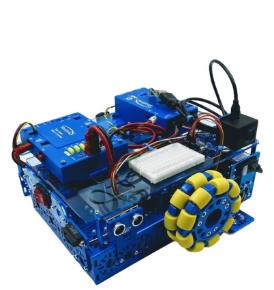
    STEM BOT Pro Kit - Parts List

    (Download to View STEM BOT Parts List as PDF)

    Note: 3D CAD files for all parts are available at www.studica.com/studica-robotics-resources

    Controllers included in the STEM BOT Pro Kit:

    • VMX Robotics Controller 
      • The Studica Robotics VMX Robotics Controller can be used an a Robot Control System or Vision/Motion processor, supporting Java and C++.  The controller integrates the navX-IMU, Gigabit Ethernet, USB3.0 ports and built-in Wifi and Bluetooth.
      • Highly-integrated, inexpensive, WiFi-enabled, multi-core Linux computing platform with lots of USB IO for expansion.
      • 32-bit ARM Microcontroller incorporating sophisticated I/O and digital communications engines
      • Low-cost MEMs Inertial Measurement Units (IMUs)
      • Powerful software providing rich libraries and tools for developing robot control software in C++, Java
      • CAN bus for high-speed, real-time communication between devices
    • Titan Quad Motor Controller 
      • The Studica Robotics Titan Quad Motor Controller is a powerful, 4-channel CAN-based motor controller with a built-in fuse-box (for DC motors up to 20A).
    Key Features & Performance
    • Networking Speed: Provides a networking link of up to 12 Mbps using the Point-to-Point Protocol (PPP).
    • Protocol Support: Transports multiple protocols, including CAN and MAVLink, over the network without exhausting multiple serial ports.
    • Processor: Powered by a dual-core Arm Cortex-M7 (480 MHz) and Cortex-M4 (240 MHz) architecture with high-speed embedded memories (2MB Flash, 1MB RAM).
    • Compliance: The device is NDAA compliant, with components sourced and assembled in Allied nations.
    Compatibility
    • Flight Controllers: Native support is available for Cube Orange+ and Cube Red running ArduPilot 4.5 or higher. Older Cubes may require custom ArduPilot builds with networking enabled.
    • Software Ecosystem: Compatible with the Cube Autopilot ecosystem and UAVCAN/DroneCAN devices. 
    EV SSL